Online Risk-Bounded Graph-Based Local Planning for Autonomous Driving with Theoretical Guarantees
Published in 2025 IEEE International Conference on Robotics and Automation (ICRA), pp. 16685-16691, 2025
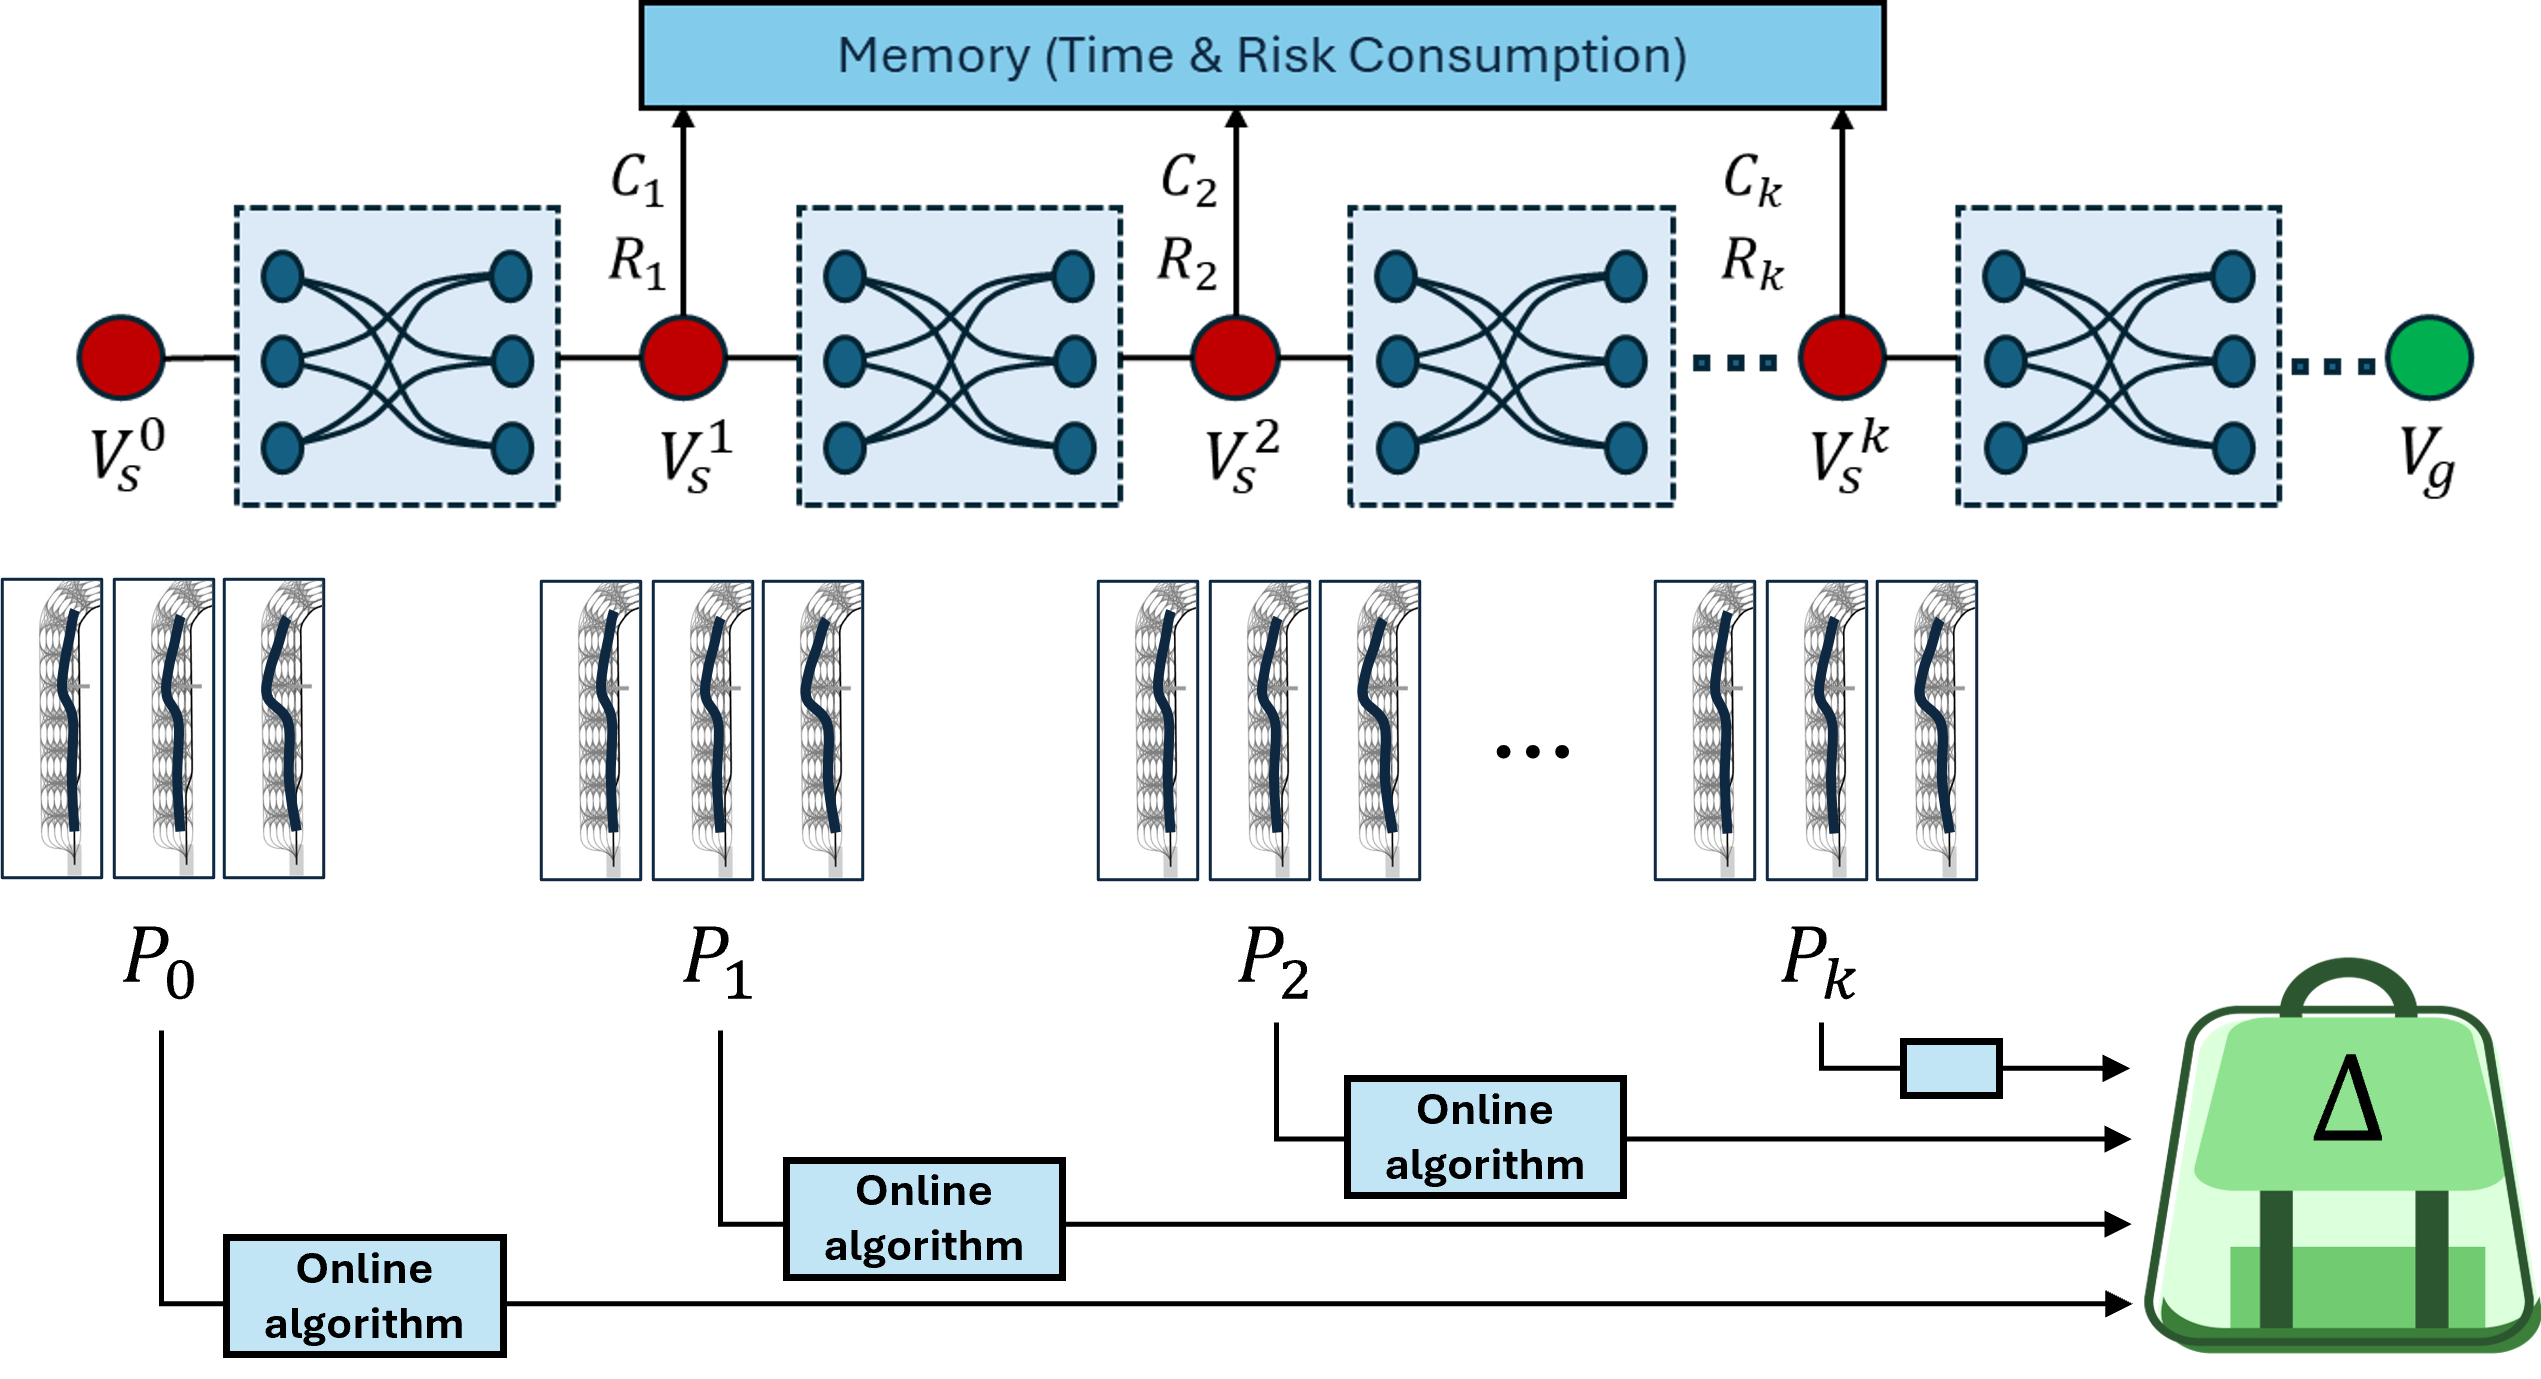
This paper develops an online graph-based local planner for autonomous driving with explicit risk bounds and theoretical guarantees.
The method targets real-time decision-making in uncertain traffic environments while preserving safety and tractability.
Recommended citation: Abdulrahman Ahmad, Majid Khonji, Khaled Elbassioni, Jorge Dias, and Ameena Al-Sumaiti. (2025). "Online Risk-Bounded Graph-Based Local Planning for Autonomous Driving with Theoretical Guarantees." 2025 IEEE International Conference on Robotics and Automation (ICRA), pp. 16685-16691.