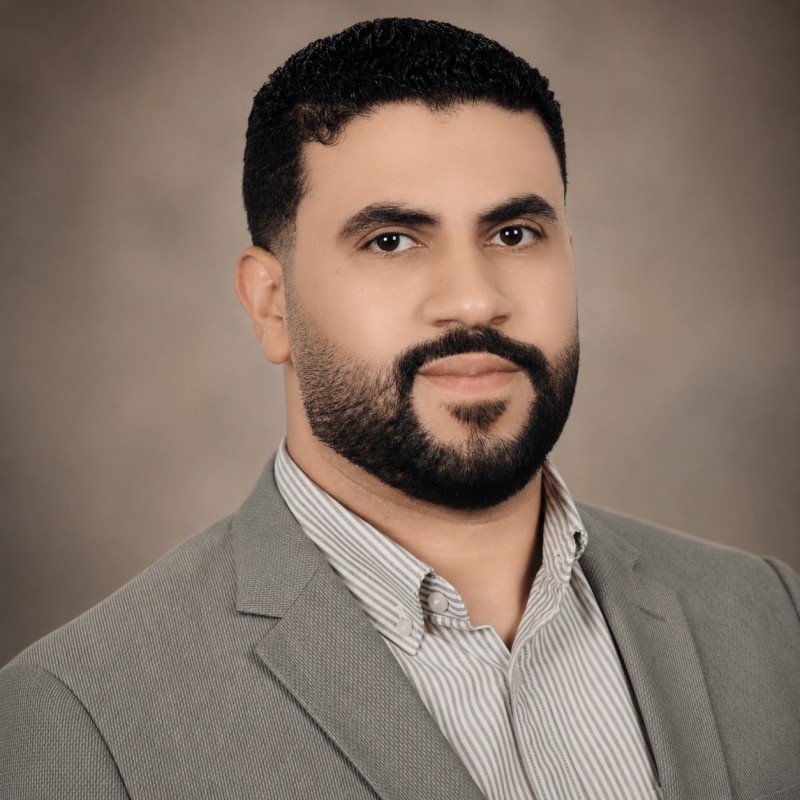
Abdulrahman Ahmad
Computer Science Ph.D. Candidate | Khalifa University
Building risk-aware autonomy for intelligent transportation systems
I am Abdulrahman Ahmad, a final-year Ph.D. candidate in Computer Science working at the intersection of autonomous driving, motion planning under uncertainty, intelligent transportation systems, and data-driven perception. My research focuses on decision-making and control methods that remain safe, tractable, and deployable in real traffic environments.
Research Focus
My work connects optimization, control, and learning for safer and more efficient autonomous systems. Each area below links to a dedicated project page.
Autonomous Driving
Risk-aware motion planning and control
I develop local planning and control methods that account for uncertainty, spatiotemporal risk, and real-time decision constraints in mixed urban traffic.
Transportation Systems
Signal control, eco-driving, and emergency prioritization
I study how connected and autonomous vehicles can improve traffic efficiency through signal-aware control, network-level coordination, and emergency-vehicle prioritization.
Learning and Control
Interaction-aware and learning-based autonomy
My research combines reinforcement learning with classical control and optimization to design robust controllers for challenging autonomous systems.
Perception and Data
Trajectory prediction and benchmark datasets
I contribute to trajectory-prediction surveys, dataset design, anonymization tooling, and data-driven benchmarks that support real-world autonomous-driving research.
Selected Publications
Representative work across motion planning, transportation systems, and perception for autonomous driving.
ICRA 2025
Online Risk-Bounded Graph-Based Local Planning for Autonomous Driving with Theoretical Guarantees
Introduces an online graph-based local planner with explicit risk bounds for autonomous driving in uncertain traffic environments.
Information Fusion
Trajectory Prediction for Autonomous Driving: Progress, Limitations, and Future Directions
Surveys the trajectory-prediction landscape, identifies major limitations, and outlines open directions for robust real-world forecasting.
IEEE T-ITS
Multiple Intelligent Control Strategies for Travel-Time Reduction of Connected Emergency Vehicles
Develops intelligent control strategies for connected emergency vehicles to reduce travel time and improve network responsiveness.
Dataset and Benchmarking
EMT: A Visual Multi-Task Benchmark Dataset for Autonomous Driving in the Arab Gulf Region
Presents a benchmark dataset tailored to multiple perception and scene-understanding tasks for autonomous driving research.
Recent Updates
Selected recent publications, datasets, and research milestones.
Priv-DATA presented for privacy-aware autonomous-vehicle dataset release
Introduced Priv-DATA, a privacy-aware dataset anonymization tool designed for autonomous-vehicle research workflows and public data release.
Self-supervised plankton classification preprint released
Published a new preprint on self-supervised plankton classification using DINO features and gradient-based loss re-weighting.
Trajectory-prediction survey published in Information Fusion
Published a survey on trajectory prediction for autonomous driving, covering progress, open limitations, and future research directions.
ICRA paper on online risk-bounded local planning
Presented an online graph-based local planner for autonomous driving with explicit risk bounds and theoretical guarantees.
Academic Profile
A concise overview of current roles, recognition, and research infrastructure.
Current Roles
Research and academic appointments
- Graduate Research and Teaching Assistant at Khalifa University since 2021.
- Researcher in the Autonomous Vehicles Lab and former researcher in the Operations Research Lab.
- Teaching experience across programming, data science, control, algorithms, and robotics.
Recognition
Awards and academic distinction
- Elite Young Researcher, Khalifa University, 2023-2024.
- Recognized as a Future Expert on the UAE Research Map national platform in 2026.
- M.Sc. in Electrical Engineering and Computer Science from Khalifa University with a CGPA of 4.0/4.0.
Service
Peer review and community contribution
- Reviewer for IEEE Transactions on Intelligent Transportation Systems and IEEE Transactions on Industry Applications.
- Reviewer for IEEE Access, ICRA, IROS, and ICARCV.
- Educational outreach through the khawarizmiat YouTube channel and course playlists.
Toolchain
Research platforms and engineering stack
- CARLA, ROS 2, NAV2, RViz2, Foxglove, Autoware, CommonRoad, RoadRunner.
- PTV Vissim, SUMO, MATLAB, Simulink, Jupyter, Docker, and Linux.
- Primary development in Python, C++, C#, MATLAB, and Git-based workflows.
Profiles and Contact
Additional academic profiles and direct contact information.