Graph-Based Local Planning with Spatiotemporal Risk Assessment for Risk-Bounded and Prediction-Aware Autonomous Driving
Published in 2024 18th International Conference on Control, Automation, Robotics and Vision (ICARCV), pp. 1–8, 2025
This paper studies risk-bounded motion planning for autonomous driving in dynamic environments with both static and moving obstacles.
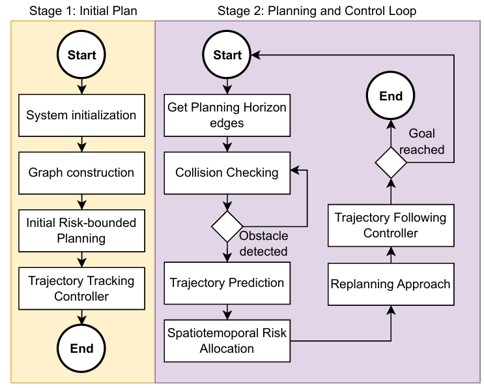
The proposed method uses a lattice-based local planner with spatiotemporal risk assessment and a constrained shortest-path formulation that respects vehicle-curvature constraints.
The system is designed for urban driving scenarios and explicitly accounts for safety margins, prediction uncertainty, and user-defined risk preferences. 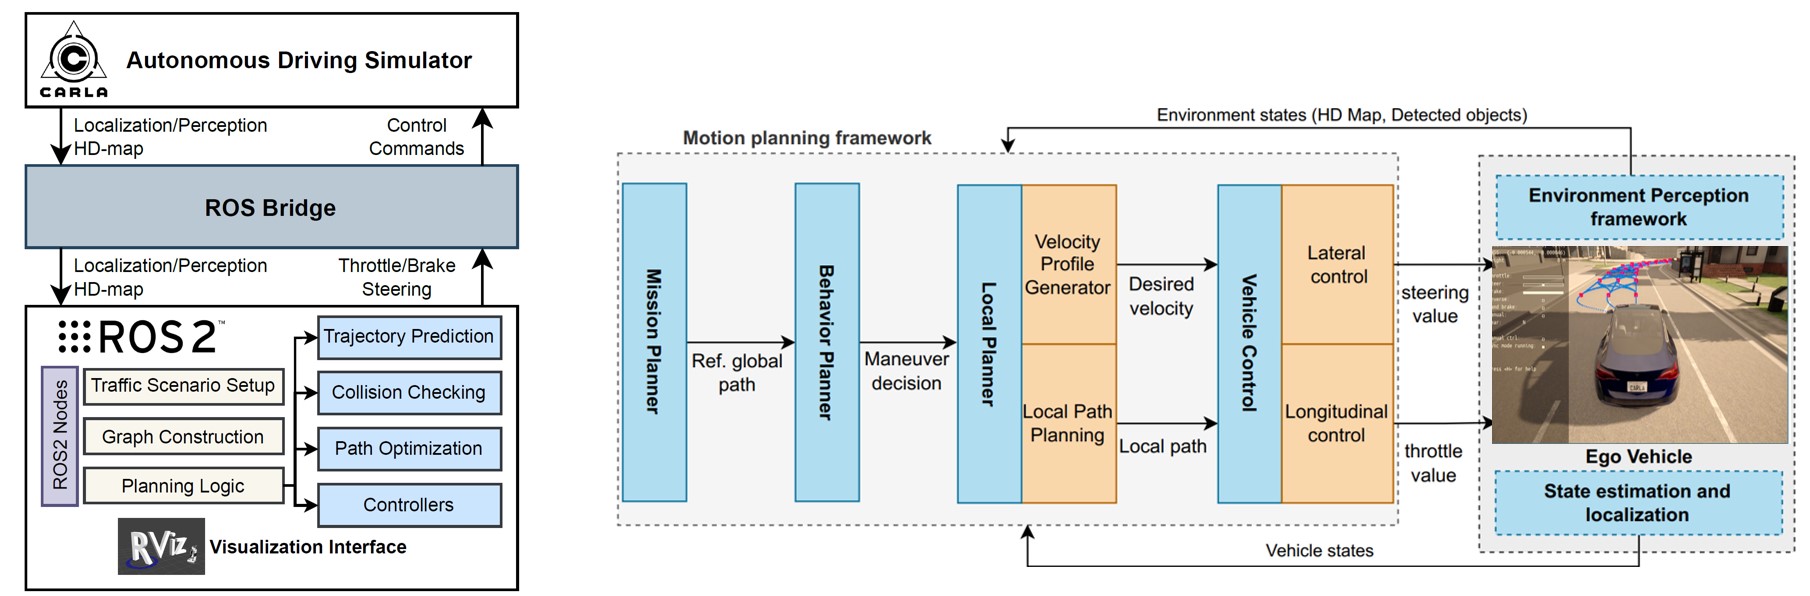
Demo Video
Recommended citation: Abdulrahman Ahmad, Majid Khonji, Ameena Al-Sumaiti, Jorge Dias, and Khaled Elbassioni. (2025). "Graph-Based Local Planning with Spatiotemporal Risk Assessment for Risk-Bounded and Prediction-Aware Autonomous Driving." 2024 18th International Conference on Control, Automation, Robotics and Vision (ICARCV), pp. 1-8.